

Electronics engineer with a passion for DIY. Always building, exploring, and taking on new challenges. Check out my projects at https://nitter.cf/t.co/ipwKkpOuYq.
Portugal
Joined February 2020
- Tweets1.4K
- Following897
- Followers1.3K
- Likes35.5K




Pinned Tweet
My main project for 2026 (and onward if it goes well):
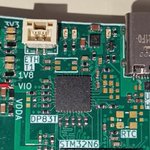
The PlumeN6 HD:
- STM32N6 MCU
- MIPI-CSI interface
- MJPEG and H.264 encoder
- USB-HS
- 1000Base-T1 Eth.
- ESP32-C5 (maybe)
Planned to be used first in either a custom small drone (Andorinha) or a MobED style robot (Lince).

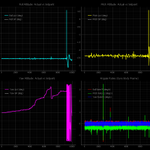
So current issue is, while stationary after about 20-30min the estimator (EKF) output starts oscillating and crashes... The plot shows this moment.
I think it is yaw integration and covariance going to high (yaw without MAG has no real correction).
Time to debug and fix this!


Major updates to the robotics/drone controller firmware I'm working on for my #PlumaN6 board:
- Reading IMU, Baro, etc
- Fusing them with Invariant EKF
- Publish Mavlink msgs for QGroundControl
The Invariant EKF filter is not yet very stable but a good starting point is reached!
So current issue is, while stationary after about 20-30min the estimator (EKF) output starts oscillating and crashes... The plot shows this moment.
I think it is yaw integration and covariance going to high (yaw without MAG has no real correction).
Time to debug and fix this!
Major updates to the robotics/drone controller firmware I'm working on for my #PlumaN6 board:
- Reading IMU, Baro, etc
- Fusing them with Invariant EKF
- Publish Mavlink msgs for QGroundControl
The Invariant EKF filter is not yet very stable but a good starting point is reached!
Major updates to the robotics/drone controller firmware I'm working on for my #PlumaN6 board:
- Reading IMU, Baro, etc
- Fusing them with Invariant EKF
- Publish Mavlink msgs for QGroundControl
The Invariant EKF filter is not yet very stable but a good starting point is reached!
Firmware GitHub for the curious (also with custom drivers for the STM32N6 😉):
github.com/NotBlackMagic/Ins…


First capture of the new camera module I added to the #PlumaN6, the OV9281 Global Shutter BW camera module.
It's connected via the parallel DCMI port, leaving the MIPI-CSI for high resolution camera (dual camera setup!).
It will be used down-facing and used for optical flow.

Got the new soldering station from JBC at work, had the older one before with the blue/white screen.
Love JBC, but this new station takes over 60s to boot!! What is it doing?! It's a fancy PID controller....

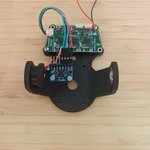
It's coming along. Had a hard time to get it to move (not unpredictably) when mounting the IMU to the arm.
Turns out that the alignment/calibration procedure of the PHI_E (motor poles) and the IMU angle is crucial! Who would have thought... 🙃
They finally launched it! Just ordered one, was able to snag the super early bird one.
Can't believe they got it out for the price... Really looking forward to using it!

The World's First 10Gbps USB3.2 Logic Analyzer launch on Kickstarter now!
Upto 1.4G@4CH, 800M@8CH, 400M@16CH, 200M@16CH, 4x 100Msps ADC module, and AI Agent Ready!
Check it now, Get $99 super early bird:
kickstarter.com/projects/sip…

It's Alive!
First movements achieved! Not how it will work in the future, only for testing. Test was using the FOC in closed-loop with feedback angle from IMU. This is not the intended operation but was a nice little effect, the IMU will be mounted to the gimbal itself.
Further progress on this issue:
I can now flash the firmware using USB DFU from visual code and then wait on debugger connection, connected in hot plug mode.
So basically back to "developer mode" work flow but without needing developer mode.
#embedded #stm32n6 #pluman6
Created a test stand so I can mount my mini gimbal and develop it away from the drone.
Also, the gimbal controller board is now sully populated, with all 3 highly integrated FOC controllers!
Next let's get some movement going!

Anybody experience with Automotive Ethernet PHYs (1000BASE-T1)?
I added it to my PlumaN6 board, but I never worked with it so will be interesting! (Yeah missing the coil and oscillator still)
Some recommended adapter to "standard" gigabit Ethernet?

Found a workaround in the weekend!
FW needs to enable debugging, else it is OFF. Then we can Hot-Plug a debugger.
But how to load FW without debugger?
Using USB DFU, which still works! So: load FW into SRAM via DFU, enable debugger, connect with Hot-Plug!
Not elegant but works!
Seems I just bricked, mostly, another #Stm32n6...
The BOOT1 stays low, whatever I apply to the default pin (PA6), and even after changing the pin to another using the OTP no change...
I then erased the external flash which leaves me without ANY way to connect a debugger...
Seems I just bricked, mostly, another #Stm32n6...
The BOOT1 stays low, whatever I apply to the default pin (PA6), and even after changing the pin to another using the OTP no change...
I then erased the external flash which leaves me without ANY way to connect a debugger...
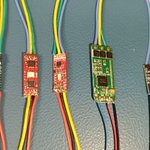
Collection of the cheapest BLDC motors drivers I could find on AliExpress.
To test for my drone project, with different motors, voltages, etc...
Curious to see how long they survive 😂

More progress on the Andorinha Drone Project (powered by PlumaN6):
Testing of the fit of the new V2 drone arm, foldable downward and with mounting holes for a prop guard (planned). Arm mount for a 1503 BLDC and Max 150mm prop.
The drone is gaining shape!
