

Bosch Research | CMU PhD
Joined May 2021
- Tweets73
- Following221
- Followers237
- Likes912




Peter Schaldenbrand retweeted

Inspired by @johnzhangx's work, I wanted to see if we could bring agentic real2sim to space robotics! 🚀🛰️
Using footage of Canadarm2 (@csa_asc) operating aboard the ISS, I reconstructed the scene in simulation using RoboSimStudio with mjorbit support!
robosimstudio.github.io/

Peter Schaldenbrand retweeted

introducing mjorbit: an open-source simulator for space robotics that runs thousands of worlds in parallel on a GPU.
here, a single RL policy trained in mjorbit flies in from kilometers away in LEO, grabs a satellite with both arms, and points it at earth 🧵
The Arts & Robotics session will return to ICRA'27 in Seoul! The call for contributions is open with a deadline of December 1st 2026
2027.ieee-icra.org/contribut…
Looking forward to seeing your work :)
10
361
Peter Schaldenbrand retweeted

VLAs can do a lot zero-shot. But when one fails, there's no way to tell it what went wrong - you collect more demos and retrain.
What if you could just say something?
Introducing ARCHITECT 🤖👷: a robot coding agent that synthesizes policies from free-form language instructions.
robo-architect.github.io/
🧵1/N
Peter Schaldenbrand retweeted

RIO, a new framework from CMU, provides a unified interface for robot control, data collection, teleoperation and AI deployment!
It gives researchers a lightweight, modular foundation for deploying robots quickly on any platform.
ri.cmu.edu/robot-io/

Recently got to show Pittsburgh Mayor @CoreyOConnorPA some robots at Bosch but didn’t have time to tell him about my ideas for public transportation (dense network of ski lifts)

Peter Schaldenbrand retweeted
How can we get robot hands to “hear” slip and contact through microphones, and react to them?
We’re excited to share VibeAct, an approach that uses piezoelectric microphones embedded in robot fingertips to estimate contact and slip, then learns reactive policies from this tactile feedback!
vibeact.github.io
Peter Schaldenbrand retweeted
Excited to share SoftAct, a framework for retargeting human manipulation demos to soft robot hands using explicit contact force reasoning! How do you transfer human skill to a hand that looks and moves nothing like yours🐙🖐️? It turns out VR environments can let us capture privileged force interaction demonstrations to help. 🧵1/7
Peter Schaldenbrand retweeted
super excited to announce our full-day workshop on Contact-Rich Control and Representation (CR2) at #ICRA2026, held on June 1st in Vienna, Austria!
🕸️ website:
for all information, please check out: cr2-icra2026.github.io

Peter Schaldenbrand retweeted

One month to go until we close the open call for @CVPR Art Gallery🤖🎨
Last year we had everything from rotting apples and interactive robots to multiscreen sculptures.
I can't wait to see what people submit this year😍
Details: tinyurl.com/CVPR2026
#CVPR2026 #creativeAI


EXTENSION! The ICRA Arts & Robotics call for proposals has been extended to Jan 9th!
2026.ieee-icra.org/contribut…
Photo of @p_alvesoliveira 's group last year!

ALT Researchers sit behind a table with a robot and computer monitor on it. The robot is holding a paint brush. In front of the table are several abstract paintings that were co-created with a human and robot.
Peter Schaldenbrand retweeted

1/N
🎨🤖Given only a static image of an oil painting by an expert artist, can a robot infer the corresponding control actions, such as trajectory, orientation, and applied force, to accurately reproduce the painting?
🖌️Introducing IMPASTO: a robotic oil-painting system that integrates learned pixel dynamics with model-based planning to reproduce paintings from target images.
This project is led by @yingke_wang18 (wykac.com/) – a roboticist and an artist.
Project website: impasto-robopainting.github.…
The ICRA Arts & Robotics call for proposals is Dec. 22! Looking forward to seeing some more amazing demos in Vienna!
More info here: hoomansamani.com/arts-robots…

Had a great time at my first SIGGRAPH! Thanks @YVinker and @Miamiamia0103 for organizing a super cool workshop and for the sick bookmark 👩🎨

1
17
634
Peter Schaldenbrand retweeted

Wrapping up our first Drawing & Sketching workshop at #SIGGRAPH2025 🙌!
Thanks to everyone who joined us. We were thrilled to see so much excitement for this field!
Huge thanks to our interdisciplinary line of speakers for sharing their valuable insights.
See you next year :)


Peter Schaldenbrand retweeted

👨🎨 Evaluation of Human & Robot Art 🎨
Seeking for #art #curator, #art #critique, #art #historian based in the US, to evaluate human & robot art!
🖌️ Enroll here: lnkd.in/dcKM-kKp
The survey takes 15min and you will receive a compensation of $50 ❤️
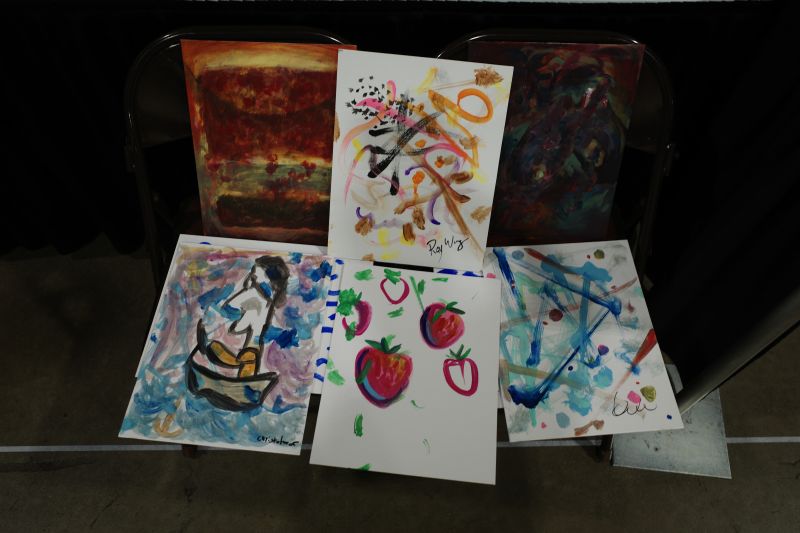
The Arts in Robotics session at @ieee_ras_icra is in full swing! Different demos am and pm every day. It's located in the corner of the expo room!


Sim2Real (pydiffvg to real) gap is super tough. We usually use canvas board to avoid the wet paper buckling. Check out our work, Spline-FRIDA, which learns all those z parameter calibrations automatically. It's still differentiable too. arxiv.org/abs/2412.00597

Trying to translate the strokes I generated with pydiffvg onto paper.
And again the difficult part is finding the right z values which depend on the desired stroke width, the correct calibration of the plane and how much the paper starts to buldge when it gets wet.
2
5
425
Peter Schaldenbrand retweeted

We are launching a new platform to build a diverse and friendly multicultural community. Please sign up to join our waitlist or try the Beta version to earn points by posting your photos or explore other cultures in the world!
worldccub.netlify.app/
#WorldPeace #WorldCCUB
