
PhD student at Université de Montréal and @Mila_Quebec. Embodied AI, Robotics, 3D perception. @Apple intern.
Montreal, Canada
Joined October 2016
- Tweets93
- Following513
- Followers662
- Likes407


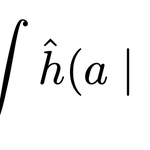




Pinned Tweet
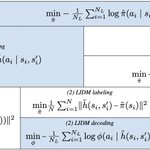
Action labels for BC are not cheap. Semi-supervised methods use Inverse Dynamics Models (IDMs) to fix this, but why does IDM learning actually outperform BC in this context?
Our #ICML2026 paper answers this! 🇰🇷
📜 Paper: arxiv.org/abs/2602.02762
🧵

Sacha Morin retweeted

Greetings from Seoul! 🇰🇷
Excited to be at ICML 2026 presenting our paper today, "Can Computational Reducibility Lead to Transferable Models for Graph Combinatorial Optimization?"
(spoiler: yes)
📍 Thu Jul 9, 2:30–4:15 PM KST, Hall A, #2502
(1/n)

Sacha Morin retweeted

While everyone debates WAMs vs. VLAs for robotics, AI Agents are quietly outperforming end-to-end policy-based methods across many tasks and benchmarks.
This is because AI Agents don't start from zero. They leverage decades of hardened CV + robotics research tooling (e.g. Physics, SAM, grasping, motion planning).
VLAs, meanwhile, require expensive post-training to learn task-specific knowledge from scratch, hence the scaling bottleneck.
Incredibly excited to be part of Graph-as-Policies (GaP)—the latest leap in Agentic Robotics led by @keplerccccc , @Shuangyu0_0Xie, and @Ken_Goldberg from @berkeley_ai

Graph-as-Policy (GaP) is a new variant of Agentic Robotics from @NVIDIA and @UCBerkeley that builds computation graphs (like ROS) to ensure modularity, manage complexity, and facilitate interpretability.
🧵Open code and paper: graph-robots.github.io/gap/
#Robotics #Automation #AgenticAI #EmbodiedAI
Sacha Morin retweeted

🚀 New Preprint Out!
🔍 “𝐂𝐚𝐧 𝐌𝐨𝐝𝐞𝐥 𝐌𝐞𝐫𝐠𝐢𝐧𝐠 𝐈𝐦𝐩𝐫𝐨𝐯𝐞 𝐀𝐠𝐠𝐫𝐞𝐠𝐚𝐭𝐢𝐨𝐧 𝐢𝐧 𝐃𝐢𝐋𝐨𝐂𝐨?” We tackle this question in our latest work, showing that model merging-inspired pseudo-gradient aggregation can improve DiLoCo’s outer optimizer. Our proposed 𝐈𝐬𝐨𝐋𝐨𝐂𝐨 method yields better worker-count scaling than DiLoCo and even improves the scaling of the recently proposed MuLoCo across our experiments.
📜Read the paper: arxiv.org/abs/2607.03011
🧵 1/N

Sacha Morin retweeted

Presenting our work at ICML this week! Come and say hi!
On the Sample Efficiency of Inverse Dynamics Models for Semi-Supervised Imitation Learning
Poster: Wed, Jul 8, 10:30 AM KST, HALL A # 508

Action labels for BC are not cheap. Semi-supervised methods use Inverse Dynamics Models (IDMs) to fix this, but why does IDM learning actually outperform BC in this context?
Our #ICML2026 paper answers this! 🇰🇷
📜 Paper: arxiv.org/abs/2602.02762
🧵
We further investigate how a recent architecture for unified video-action prediction (UVA) can be turned into a sample-efficient, IDM-based policy for robot manipulation. We experiment on Push-T and LIBERO-10 (using 5% of action labels).

Work done at @Samsung AI Lab Montreal and @Mila_Quebec w/ Moonsub Byeon, @jm_alexia & @seblachap
Come say hi if you're at ICML!
📍 Poster: Wed, Jul 8, 10:30 AM KST, HALL A # 508
Sacha Morin retweeted
🎉 Our paper "𝗙𝗿𝗼𝗺 𝗠𝗲𝗺𝗼𝗿𝗶𝘇𝗮𝘁𝗶𝗼𝗻 𝘁𝗼 𝗣𝗮𝗿𝗮𝗺𝗲𝘁𝗲𝗿 𝗜𝗻𝘁𝗲𝗿𝗳𝗲𝗿𝗲𝗻𝗰𝗲: 𝗛𝗼𝘄 𝗢𝘃𝗲𝗿𝘁𝗿𝗮𝗶𝗻𝗶𝗻𝗴 𝗘𝘅𝗽𝗲𝗿𝘁𝘀 𝗛𝗮𝗿𝗺𝘀 𝗠𝗼𝗱𝗲𝗹 𝗠𝗲𝗿𝗴𝗶𝗻𝗴" was accepted at ICML 2026!
🔎 Do better expert models always lead to better merged models? Not necessarily!
📜Read the paper: arxiv.org/abs/2506.14126v2
🧵 1/9
At #NeurIPS this week to present two projects! Come say hi if you’d like to chat about spatial AI, 3D perception, or the current state of robotics. Details 👇

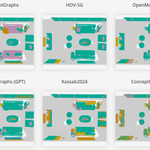
OpenLex3D: New 3D open-vocabulary benchmark.
🌐 Website: openlex3d.github.io
📑 Arxiv: arxiv.org/abs/2503.19764
⏳Poster: Friday 11:00AM Exhibit Hall C,D,E #4913 (D&B Track)
1
4
100
Agentic Scene Policies: General manipulation policy through agentic interactions with a 3D object map.
🌐 Website:montrealrobotics.ca/agentic-…
📄 Paper: arxiv.org/abs/2509.19571
⏳Poster: Sunday Upper Level Room 29A-D (SpaVLE Workshop)
3
82
🤖 Excited to share our recent work: Agentic Scene Policies!
General manipulation policy through agentic interactions with a 3D object map. Includes affordances, mobile queries and comparisons with VLAs!
📄 Paper: arxiv.org/abs/2509.19571
🌐 Site: montrealrobotics.ca/agentic-…
Fun collaboration with Kumaraditya Gupta, Mahtab Sandhu, @velythyl, Francesco Argenziano, Kirsty Ellis and my advisor @duckietown_coo. Work done at @Mila_Quebec
3
78
Sacha Morin retweeted

Next month at @NeurIPSConf: @ckassab1 will present a new benchmark for open-vocab scene understanding - OpenLex3D.
Webpage & paper: openlex3d.github.io
Co-authors: @SachMorin, Martin Büchner,
@mmattamala, @kumaraditya_gup, Abhinav Valada,
@duckietown_coo,
@MauriceFallon

Happy to share that we'll be presenting OpenLex3D at NeuRIPS in San Diego!
TLDR: New 3D segmentation and object retrieval benchmark for open-vocab 3D scene representations. Project page: openlex3d.github.io/

Huge effort with @ckassab1 , Martin Büchner, @mmattamala, @kumaraditya_gup, Abhinav Valada, @duckietown_coo & @MauriceFallon
6
116
I am very late to share this but StepMix has been accepted in the Journal of Statistical Software!
StepMix is a Python/R package for generalized mixture modeling with support for clustering and classification. Available here: github.com/Labo-Lacourse/ste….

6
173