
Robotics Research Scientist at The AI Institute | @CMU_Robotics PhD
Boston, MA
Joined November 2013
- Tweets237
- Following412
- Followers1.2K
- Likes691





The breakout sessions at the #R2RL workshop have reconvened and we now have a panel of breakout leads and speakers to guide discussion on each topic: @RKrohn_ @zhiyuan_zhou_ @xkelym @GautamSalhotra Tobias Jülg (tobiasjuelg.de) @asoare159


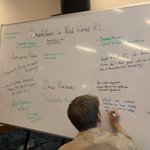
The #R2RL workshop at #CoRL2026 is now moving into short breakout sessions. Based on participant whiteboarding and voting, we’re discussing autonomous resets, value learning, data reusability, reward estimation, and damage recovery!
Session participants will prepare one slide on their discussions and findings.


The #R2RL workshop would not have been possible without our amazing organizers @Jesse_Y_Zhang, @lakshitadodeja, @yigitkkorkmaz, @shaohua0116, @smithlaura1028, Anusha Nagabandi, @gao_young, @DanicaKragic, and @abhishekunique7!
Now for some Texas barbecue 🤠

Most importantly, we thank all the speakers, panelists, and participants!
The #R2RL Workshop at #CoRL2026 put the spotlight on the practitioners of real world RL, and invited general participation through the open whiteboard, breakout sessions, and panel q&a.
This workshop exceeded our expectations because of the engaged and insightful participants. Excited to see where real world RL goes from here!
4
171
Last but not least, @zhiyuan_zhou_ is presenting a talk titled To Stability and Beyond!
For this workshop, we invited speakers who are running real-robot RL and are familiar with its bottlenecks through heavy experimentation. Find them at the coffee and poster session in Griffin for additional Q&A!

The room has been packed. @xkelym is now discussing the importance of priors in her talk, Sample Efficient RL.

1
20
1,066

The #R2RL workshop at #CoRL2026 is now moving into short breakout sessions. Based on participant whiteboarding and voting, we’re discussing autonomous resets, value learning, data reusability, reward estimation, and damage recovery!
Session participants will prepare one slide on their discussions and findings.
@Jesse_Y_Zhang kicking off the Roadmap to Sample Efficient Reinforcement Learning Workshop (#R2RL) at #CoRL2026!
We’re making RL work on real robots.
r2rl-workshop.github.io


