

Developing pervasive, persistent, and perceptive robots for the real world @UTIAS @UofTRobotics! Led by @domo_mr_roboto and located in Toronto, Canada.
Toronto, Ontario
Joined March 2015
- Tweets383
- Following46
- Followers1.1K
- Likes106





1/ 📢 We'll be at #CoRL2026! Hooray! 🤖
In just over a week we'll be in Austin (Nov 9–12) presenting our paper on the geometry of diffusion models for constrained inverse kinematics. Kudos to our PhD students Miguel Angel Rogel Garcia & @thiha_phone! 👏🧵
5/ ✅ What we found: diffusion models recover the correct dimensionality for seven different IK constraints. And small steps along the tangent space give smooth motions that stay on the constraint manifold.
6/ Come say hi if you're at CoRL this year. See you in Austin 🤠
🌐 papers.starslab.ca/diffusion…
📄 arxiv.org/abs/2606.26408
💻 github.com/utiasSTARS/Constr…
#RobotLearning #DiffusionModels #UofT
A little greed goes a long way in motion planning! 🤖
We’re excited to share that our paper “Greedy Heuristics for Sampling-Based Motion Planning in High-Dimensional State Spaces” is now published in Autonomous Robots! Led by PhD student @thiha_phone .
G-RRT* grows two trees as in RRT-Connect to find a first solution fast, and then samples mostly from the greedy informed set to converge quickly to the optimal path.
⚡️ G-RRT* also ships with VAMP, where it plans in just a few milliseconds.
Check out the project page below to run VAMP version of G-RRT* right in your browser!
:page_facing_up: arXiv: arxiv.org/abs/2405.03411
:globe_with_meridians: Project page: papers.starslab.ca/grrtstar/
#Robotics #MotionPlanning #STARSLab #RoboticsResearch #UofTRobotics
Great research happens when great people enjoy working together! ☀️
Last weekend, our lab headed over to Toronto Island for our fall BBQ: good food, sunshine and an unbeatable view of the Toronto skyline. 🌭🍔
Thank you to everyone who came out!

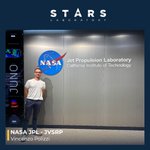
Welcome back to Toronto, @polivicio! 🚀 He just wrapped up an internship at @NASAJPL, contributing to the localization system for the Endurance lunar rover concept. 🧵 1/4

The 2023–2032 Planetary Science and Astrobiology Decadal Survey named Endurance the top priority for NASA's Lunar Discovery and Exploration Program. The rover would drive ~2,000 km collecting samples for Artemis astronauts to bring home. 🌕 🧵3/4
Great work, Vincenzo! More news from the lab soon.
📄 NASA's concept study (not our work, but a great mission overview): science.nasa.gov/wp-content/… 🧵4/4
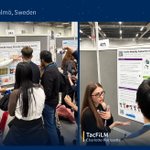
A great week at #ECCV2026 🇸🇪
Our PhD student @polivicio presented REALM.
It was also great to meet Charlotte Morissette! She recently joined the lab as a PhD student, and at ECCV she presented her master's project TacFiLM.

🚀 REALM is out: run RGB-trained decoders directly on event camera data, zero-shot.
Code, models, and an interactive demo are live.
(Clip: REALM inside MASt3R-SLAM — not in the paper.)
📄 ECCV 2026 - @polivicio, @DaveLindell, @domo_mr_roboto
🔗 papers.starslab.ca/realm/ 1/5🧵
🔹 Zero-shot geometry: events → MASt3R gives SOTA event-image matching and pose estimation
🔹 One encoder, many tasks: depth, segmentation, reconstruction, wide-baseline matching — all from linear heads trained only on RGB
🔹 LoRA adaptation, no catastrophic forgetting 4/5🧵
Come find Vincenzo at ECCV — Thu 10 Sept, 4:30 PM, ExHall, Poster Session 2, board 343.
See you in Malmö 🇸🇪! @eccvconf 5/5🧵