

@CMU_Robotics • bosch research •🚂 purdue alum
Pittsburgh, PA
Joined April 2021
- Tweets43
- Following477
- Followers84
- Likes1.2K




Revanth S ✈️ CoRL '26 retweeted

@revvozz is presenting REMM now in the poster session at JW Marriot 2nd floor.

Revanth S ✈️ CoRL '26 retweeted

Introducing EgoX: a cross-embodiment learning framework that trains manipulation policies across diverse embodiments using data from humans, physical robots, and simulated robots.
We cover highly heterogeneous embodiments: humans, physical and simulated humanoids, wheeled bimanual robots, tabletop arms, and quadrupeds. Their end effectors include three- to five-fingered dexterous hands, two-fingered and parallel-jaw grippers, and a fixed tool.
One recipe, any embodiment.
egox-dream.github.io/
Revanth S ✈️ CoRL '26 retweeted
• Project page: egox-dream.github.io/
• Code: github.com/egox-dream/egox
• Paper: egox-dream.github.io/assets/…
EgoX team: Yaru Niu, @chen_bingh85992, @changweiyao77, @ShangtaoLi, Zhenlong Fang, @revvozz, @ShuaiZhou234190, @YueminMao, @kalieching, Po-ju Chao, Yudong Luo, @PeiqiYu1019, Heng Zhang, Hao Zhang, Bingqing Chen, Chen Qiu, H. Eric Tseng, @_ye_yuan, @UmarIqb, @ChangliuL, @jonmfranc, @zhao__ding
@cmusafeai @CMUMeche @CMU_Robotics

Find me at the #CoRL2026 Learn@Deploy poster session today with REMM!
📍 JW Marriott, Room 205
🕥 10:30–11:00 a.m. CT
Excited to chat about long-horizon manipulation, memory architectures, and my current work on cross-embodiment learning!

Introducing REMM: Revisable Embodied Memory for Manipulation.
Robot memory needs to do more than retain past observations. If an intervention undoes an earlier step, the robot also needs to work out which completed conditions no longer hold and what needs to be repaired.
REMM links task state to supporting visual evidence. When that evidence changes, it revises the affected conclusions and schedules a repair around a frozen G0.5 manipulation policy. Real robot experiments are done on the @GalaxeaDynamics R1Lite.
📄 arXiv: arxiv.org/abs/2610.12710
🌐 Project: revanthsenthil.github.io/rem…
1/8 🧵
#Robotics #RobotLearning
5
154
Revanth S ✈️ CoRL '26 retweeted
Attending #CoRL26 in Austin, TX. We are presenting 3 papers.
Main: @Bw_Li1024 is presenting our work on ReSYNC; @Shuangyu0_0Xie and @kaiyuan_c are presenting our work on Graph-as-Policy (GaP)
Learn@Deploy workshop: @revvozz is presenting our work on REMM tomorrow at 10:30am.


At #CoRL2026 Mon–Thu! Presenting REMM at Learn@Deploy’s poster session Thursday, 10:30–11am.
Would love to chat about long-horizon reasoning & cross-embodiment learning! Also exploring PhD and full-time research opportunities. DMs open!
Introducing REMM: Revisable Embodied Memory for Manipulation.
Robot memory needs to do more than retain past observations. If an intervention undoes an earlier step, the robot also needs to work out which completed conditions no longer hold and what needs to be repaired.
REMM links task state to supporting visual evidence. When that evidence changes, it revises the affected conclusions and schedules a repair around a frozen G0.5 manipulation policy. Real robot experiments are done on the @GalaxeaDynamics R1Lite.
📄 arXiv: arxiv.org/abs/2610.12710
🌐 Project: revanthsenthil.github.io/rem…
1/8 🧵
#Robotics #RobotLearning
13
241
Revanth S ✈️ CoRL '26 retweeted
Thrilled to see our work Humanoid Touch Dream (HTD) contributes to Bosch Center for AI’s Outstanding Research Organisation award at the Humanoid Robotics Industry Awards 2026! 🏆 Congratulations to BCAI and the entire team!
And finally, HTD is fully open-sourced (whole-body controller, data collection, policy training and deployment, baselines)! Check it out here: github.com/chrisyrniu/humano….


We're proud to announce the winners of the Humanoid Robotics Industry Awards 2026!
Your winners:
⭐ Industry Leadership: @theermann, @dynamicreatures, Founder & CEO
⭐ Outstanding Company: @TheHumanoidAI
⭐ Outstanding Research Organisation: @BoschGlobal Center for Artificial Intelligence
⭐ Groundbreaking Technology: @ManusMeta
⭐ Best Use of AI: @AGIBOTofficial
From everyone at Humanoid Robotics Technology and our awards partner Novanta Inc.: a big thank you to everyone who nominated and voted this year, and a massive congratulations to all our winners and finalists for their outstanding contributions to advancing humanoid robotics and shaping the future of the industry.
Check out the full announcement here for more info: humanoidroboticstechnology.c…
#humanoid #humanoidrobots #humanoidrobot #humanoids

Introducing REMM: Revisable Embodied Memory for Manipulation.
Robot memory needs to do more than retain past observations. If an intervention undoes an earlier step, the robot also needs to work out which completed conditions no longer hold and what needs to be repaired.
REMM links task state to supporting visual evidence. When that evidence changes, it revises the affected conclusions and schedules a repair around a frozen G0.5 manipulation policy. Real robot experiments are done on the @GalaxeaDynamics R1Lite.
📄 arXiv: arxiv.org/abs/2610.12710
🌐 Project: revanthsenthil.github.io/rem…
1/8 🧵
#Robotics #RobotLearning
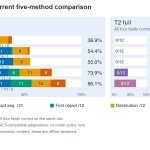
The sequence diagnostics distinguish recalling the cues from grounding them into an action.
For full T2 credit, the exact sequence, first object, destination, and command must all be correct on the same clip. REMM gets 8/12, compared with 5/12 for RoboMME-style and 0/12 for the other baselines.
The partial-score bars show which components were recovered even when the full decision was wrong. This matters because a correct sequence can still lead to an incorrect object or command.
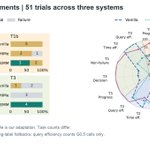
For T3, REMM’s specialized tracker selects the target in 30/30 fixed renders. That result is specific to this controlled diagnostic set.
7/8 🧵

1
50
The question behind REMM is how a robot should connect a change in evidence to a change in what it does next.
Retaining history is part of that. Keeping track of which conclusions the history still supports—and reopening the right task obligation when support is lost—is the part we make explicit here.
Joint work with @ruwantw, Alessandro Oltramari, and @jonmfranc, across @CMU_Robotics @CarnegieMellon and Bosch Center for AI.
📄 arXiv: arxiv.org/abs/2610.12710
🌐 Videos, method, and results: revanthsenthil.github.io/rem…
8/8 🧵

1
43
Revanth S ✈️ CoRL '26 retweeted
We open-sourced all components of the HTD whole-body controller (WBC): github.com/chrisyrniu/IsaacL…
-Play our WBC on your browser: humanoid-touch-dream.github.…
-Main HTD codebase entry: github.com/chrisyrniu/humano… (data collection and HTD policy soon!)
Highlighted features:
-Lightweight decoupled WBC that can be trained on a single GPU
-A stable control base for humanoid loco-manipulation (in a mobile-manipulation style)
-Support a wide range of body poses including extreme ones
-Isaac Sim/Lab training, zero-shot deployment

A touch-aware humanoid manipulation policy that cleans the lab for you🧹🧪
Introducing Humanoid Touch Dream: a real-world system for dexterous, contact-rich humanoid loco-manipulation.
Our key idea is simple: the policy predicts future hand forces and tactile latents alongside actions, within a single-stage training framework.
humanoid-touch-dream.github.…
1/7
Revanth S ✈️ CoRL '26 retweeted
A touch-aware humanoid manipulation policy that cleans the lab for you🧹🧪
Introducing Humanoid Touch Dream: a real-world system for dexterous, contact-rich humanoid loco-manipulation.
Our key idea is simple: the policy predicts future hand forces and tactile latents alongside actions, within a single-stage training framework.
humanoid-touch-dream.github.…
1/7
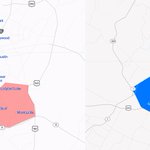
Impressive start to the geofence and the first delivery covering basically the whole width too! 👀🤖
(red - Tesla, blue - Waymo, June 2025)


World's first autonomous delivery of a car!
This Tesla drove itself from Gigafactory Texas to its new owner's home ~30min away — crossing parking lots, highways & the city to reach its new owner
1
245
