





Attending #CoRL26 in Austin, TX. We are presenting 3 papers.
Main: @Bw_Li1024 is presenting our work on ReSYNC; @Shuangyu0_0Xie and @kaiyuan_c are presenting our work on Graph-as-Policy (GaP)
Learn@Deploy workshop: @revvozz is presenting our work on REMM tomorrow at 10:30am.


@revvozz is presenting REMM now in the poster session at JW Marriot 2nd floor.

Ruwan Wickramarachchi retweeted

Introducing GR00T 2: our most advanced, open System One model for robotics. It runs entirely on your robot’s onboard compute, fully untethered, and you own every weight of it. GR00T 2 features:
1. Long-horizon tasks: dexterous manipulation and whole-body control chained over 20+ steps and 5+ minutes, such as performing chemistry lab experiments or assembling model airplanes end to end.
2. X-Adapt: adapting from easy data sources (human wearables and simulation) and deploying zero-shot to diverse real robots.
3. Unified Cognition: native integrations with frontier agents for advanced physical reasoning, robust error recovery, and safety monitoring.
It's an open-source buffet! We are releasing not only the model weights and X-Adapt recipes (coming December), but also our agentic framework, simulation engine, annotation engine, hardware design, and even training data (100K hours, that's ~11 yrs of experience), all available today!
Everything that moves will be autonomous. Anyone can become a roboticist.
Lock in, build with us!
Deep dive in thread:
Ruwan Wickramarachchi retweeted

Introducing REMM: Revisable Embodied Memory for Manipulation.
Robot memory needs to do more than retain past observations. If an intervention undoes an earlier step, the robot also needs to work out which completed conditions no longer hold and what needs to be repaired.
REMM links task state to supporting visual evidence. When that evidence changes, it revises the affected conclusions and schedules a repair around a frozen G0.5 manipulation policy. Real robot experiments are done on the @GalaxeaDynamics R1Lite.
📄 arXiv: arxiv.org/abs/2610.12710
🌐 Project: revanthsenthil.github.io/rem…
1/8 🧵
#Robotics #RobotLearning
Excited to share two papers accepted to CoRL 2026! 🎉
1. 𝗚𝗮𝗣: 𝗔 𝗚𝗿𝗮𝗽𝗵-𝗮𝘀-𝗣𝗼𝗹𝗶𝗰𝘆 𝗠𝘂𝗹𝘁𝗶-𝗔𝗴𝗲𝗻𝘁 𝗦𝗲𝗹𝗳-𝗟𝗲𝗮𝗿𝗻𝗶𝗻𝗴 𝗛𝗮𝗿𝗻𝗲𝘀𝘀 𝗳𝗼𝗿 𝗩𝗮𝗿𝗶𝗮𝘁𝗶𝗼𝗻𝗮𝗹 𝗔𝘂𝘁𝗼𝗺𝗮𝘁𝗶𝗼𝗻 𝗧𝗮𝘀𝗸𝘀
Website : graph-robots.github.io/gap/

2
5
108
2. 𝗥𝗲𝗰𝗼𝘃𝗲𝗿, 𝗗𝗶𝘀𝗰𝗼𝘃𝗲𝗿, 𝗣𝗹𝗮𝗻: 𝗟𝗲𝗮𝗿𝗻𝗶𝗻𝗴 𝗦𝗸𝗶𝗹𝗹𝘀 𝗮𝗻𝗱 𝗖𝗼𝗻𝗰𝗲𝗽𝘁𝘀 𝗳𝗿𝗼𝗺 𝗥𝗼𝗯𝗼𝘁 𝗙𝗮𝗶𝗹𝘂𝗿𝗲𝘀
Website: jaraxxus-me.github.io/ReSYNC…
2
40
Announcing Best Paper Award at IROS ReS AI workshop.
Best Paper: “iFlax: Neuro-Symbolic Learning for Long-Horizon Task Planning Under Complex Logical Constraints”
Thanks Carnegie Bosch Institute for sponsoring the best paper award.
Congratulations! 🎉
#IROS2026 #ReSAI2026


Interesting panel discussion happening now at IROS ReS AI on what semantics must the data capture for efficient robot learning, and how important is human input?
Panelists: @smash0190, @prof_yz , @maojiayuan, and Alessandra Sciutti, moderated by @jeanoh.

Namai Chandra is presenting his work on “ActionGround: Training-Free Runtime Refinement of Frozen VLA Policies” in the second oral session of IROS ReS AI 2026.
#ReSAI2026 #IROS2026

1
163
IROS ReS AI second oral talks session just stated with Guy Azran presenting his work on “Task-Aware Conformal State Estimation for Reliable Robotic Planning”
#IROS2026 #ReSAI2026

IROS ReS AI Poster session is happening now at Room 411.
#IROS2026 #ReSAI2026

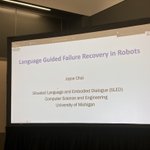
The fifth keynote at IROS ReS AI 2026 by Dr. Joyce Chai from @michigan_AI on “Language Guided Failure Recovery in Robots”
Stay tuned for an exciting poster session, followed by the second oral talks session and panel discussion.
#IROS2026 #ReSAI2026

Fourth keynote at the ReS AI workshop by Dr. Yezhou (YZ) Yang (@prof_yz) on “Evaluating AI (and AI Evaluation) as a Science: Towards Science-guided Reliable Agents”.
#IROS2026 #ReSAI2026

1
132


Third keynote at the IROS ReS AI workshop by Dr. Jiayuan Mao (@maojiayuan) from the University of Pennsylvania on “Integrated Learning and Planning with Neuro-Symbolic Concepts”.
#ReSAI2026 #IROS2026

214
Second keynote at the IROS ReS AI workshop by Dr. Sebastian Scherer (@smash0190) from the Robotics Institute at CMU on “Why robots need symbols: finite memory, long horizons, and the limits of scale”
#ReSAI2026

1
1
128
First keynote at IROS ReS AI 2026 workshop by Dr. Alessandra Sciutti from the Italian Institute of Technology on “Grounding Meaning through Embodied and Social Cognitive Development”
#IROS2026 #ReSAI2026

150
IROS 2026 the first workshop on Embodied Neuro-Symbolic AI for Reliable and Safe Robotics (ReS AI) is happening now in room 411 at the David L. Lawrence Convention Center, in vibrant Pittsburgh!
#IROS2026 #ReSAI2026 #EmbodiedNeurosymbolicAI

134